DROID
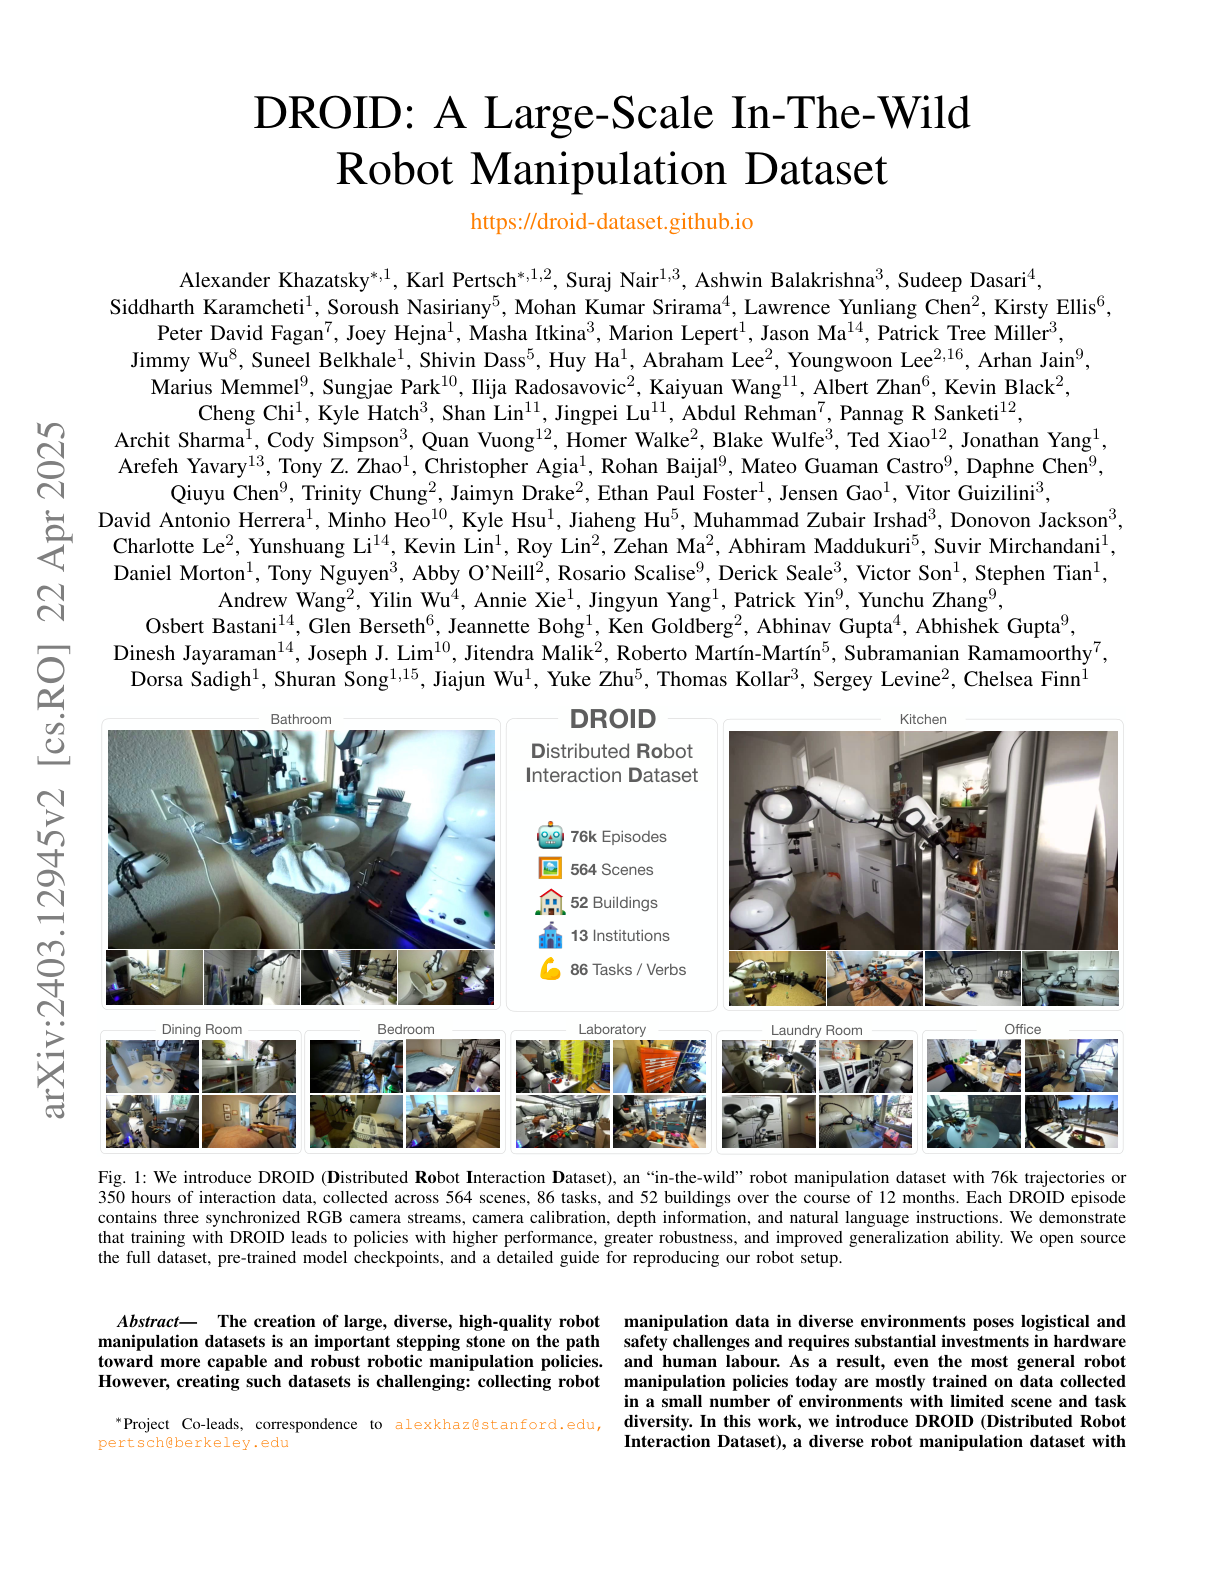
DROID is an open-source robot manipulation dataset that dramatically expands the diversity of real-world robot demonstrations available for imitation-learning research.
Ask this paper
Scale and diversity: 76K demonstration trajectories (~350 hours of interaction) collected across 564 scenes and 84 manipulation tasks - substantially more varied than prior public datasets.
Distributed collection: 50 data collectors across multiple international locations contributed over 12 months, using a standardized hardware setup that is released alongside the data.
Stronger policies: Policies trained on DROID show higher success rates and improved out-of-distribution generalization compared to training on earlier, less diverse datasets.
Full open release: Dataset, training code, and hardware reproduction guides are all public, giving the community a common substrate to benchmark and iterate on manipulation policies.