Robot Parkour Learning
First page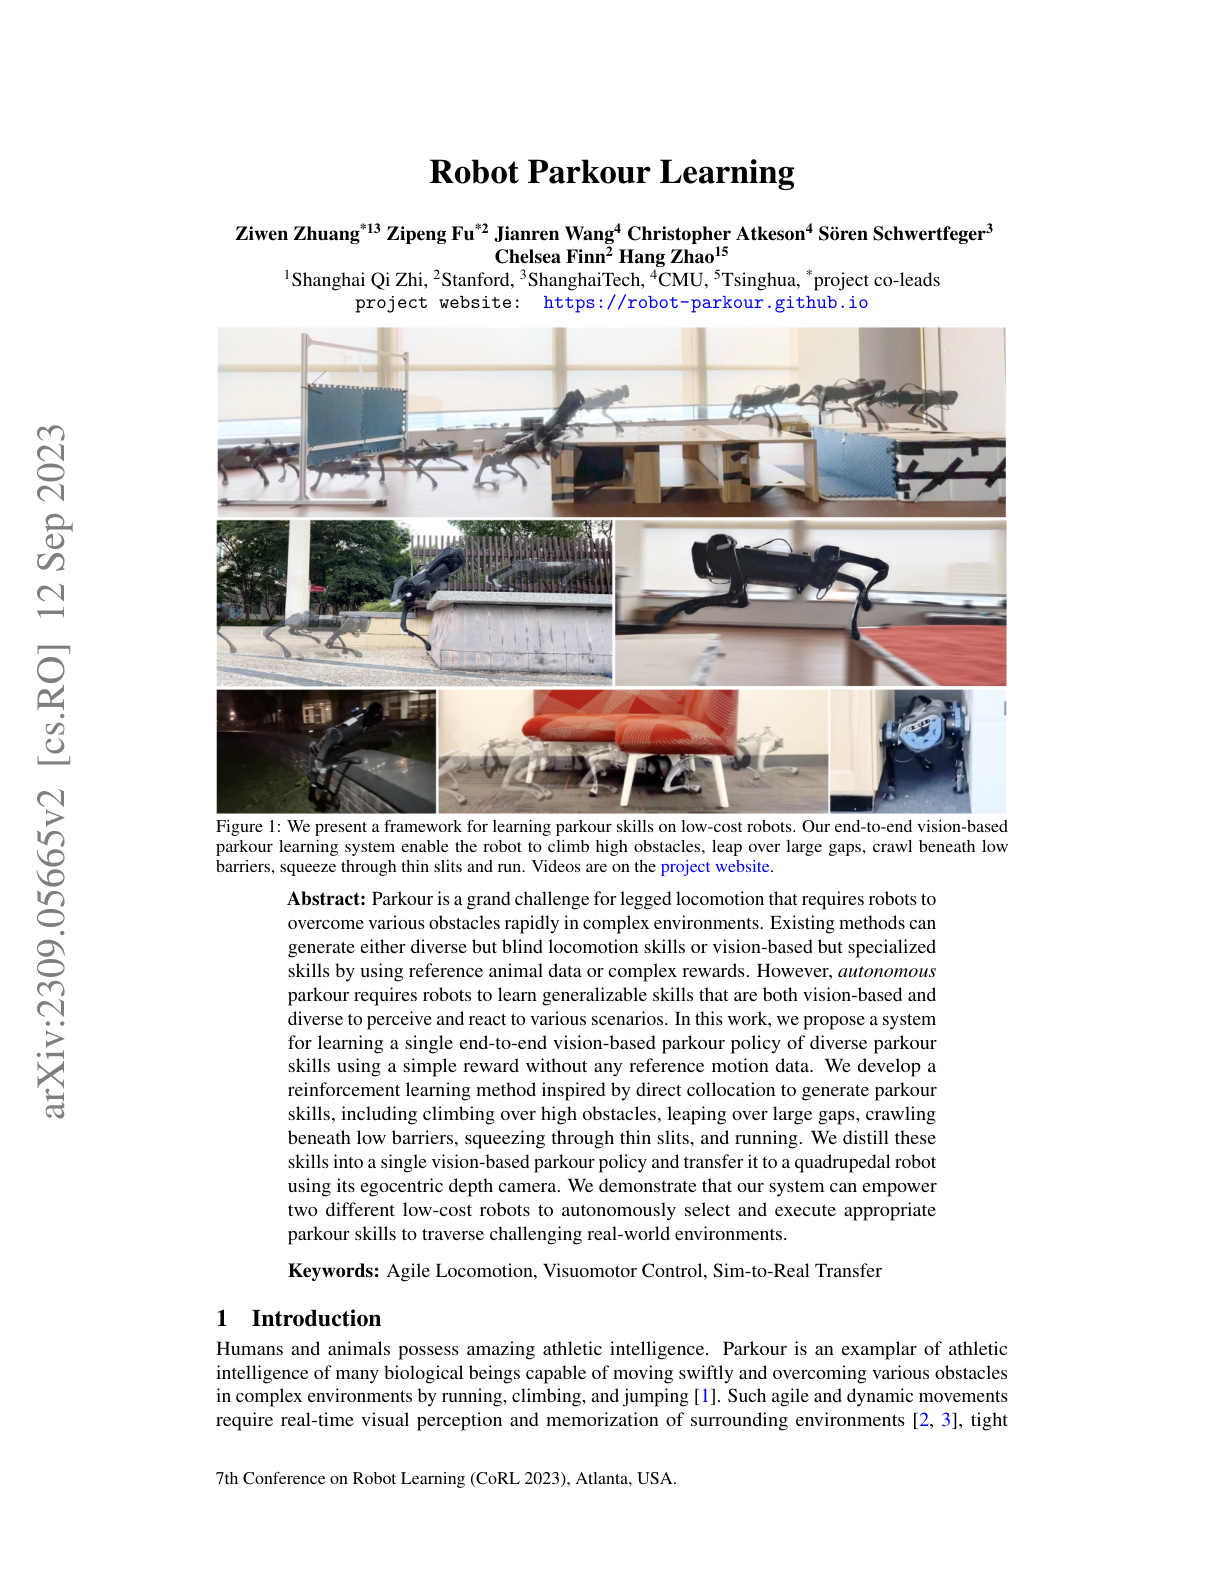
Paper summary
Stanford's Robot Parkour system learns end-to-end vision-based parkour policies that transfer to a quadrupedal robot.
Ask this paper
01
Vision-based parkour: Learns policies from an egocentric depth camera that let a quadruped execute real parkour skills like jumping gaps and climbing obstacles.
02
Sim-to-real transfer: Trained in simulation and transferred to a physical low-cost robot, demonstrating successful sim-to-real in a challenging contact-rich domain.
03
Skill selection: The policy automatically selects and sequences appropriate parkour skills based on terrain observed in real time.
04
Low-cost hardware: Runs on commodity quadruped hardware, making advanced mobile behaviors accessible to smaller labs - a recurring pattern through 2023 robotics.